Halcyon Robotics

Halcyon Robotics

Machines you can understand

Compact industrial robots for small and mid-sized businesses, and the Halcyon Pendant: the teach pendant that programs every one of them from a browser.

The Halcyon PendantHalcyon AIThe machines

The film

Halcyon in 36 seconds: one line becomes a machine, the Pendant teaches it, and it goes to work. Drawn entirely in code.

Concepts in development; every figure in the film is a design target or an example.

Sheet 01 / 07Dwg HAL-P1Scale NTS

Chapter 1

The Pendant

Teach a robot from a browser.

The Halcyon Pendant

Industrial robots are programmed with a hand-held teach pendant: jog the arm to a point, record it, play the program back. Ours runs in a browser, so a tablet or a laptop becomes the controller for every Halcyon machine, and for the arms a business already owns. Try it: hold Enable, jog the arm, record a point, then run.

Side elevation drawing of the demo armJ1 0.0 degrees, J2 75.0, J3 -105.0, J4 -60.0. Tool centre point reach 117.7 millimetres, height 85.9 millimetres. 3 recorded points.1234SIDE ELEVATION, ARM PLANEVIEW TURNS WITH J1. DIMENSIONS IN mm.J1 AXIS12375.0°J2J3J4TCPR 117.7Z 85.9PLAN, J1+0.0°LIMITS ±150°0° = FORWARDTITLEPENDANT DEMO ARMSCALE1:5SHEET1/1DRAWNHALCYONUNITSmm, DEG
HALCYON TP-1Teach pendant
Mode
MODE
T1 250 mm/s max
OVR
50%
STATE
READY

T1 manual. Hold ENABLE and jog.

Joint positions in degrees
AXISDEGRANGE
J1+0.0
J2+75.0
J3-105.0
J4-60.0
X
117.7
Z
85.9
A
-90.0
GRIP
OPEN

TCP in mm, arm frame (turns with J1). A is tool pitch in deg.

PROGRAM DEMO.PRG3 PTS LOOP

50%

Three-position enabling switch: hold it (or hold Space) with one hand and jog with the other. Release and motion stops. Enter presses a key, Esc is E-STOP.

COPILOT

Describe the job, get a draft program
PREVIEW

COPILOTIDLE

Type a job above, or pick an example, then press DRAFT PROGRAM.

Demo: a rule-based preview of the Copilot. The product drafts programs with an AI model; every draft is checked by a person in T1 before it runs.

Interactive demo. A simulated four-axis arm, not connected to hardware.

Sheet 02 / 07Dwg HAL-AIScale NTS

Chapter 2

Halcyon AI

Six tools built around the Pendant.

Halcyon AI

Six tools built around the Pendant, so a business without a robotics engineer can still set up, teach and look after its machines. In development; the drawings below illustrate each idea and every figure in them is an example.

  1. > stack 4 high on the right_P1 above pick / P2 pick, close / P3 above place 4 / ...Try it in the Pendant above

    AI-AIn development

    Pendant Copilot

    Describe the job in words; the Copilot drafts the robot program as waypoints for a person to check and run.

  2. AI-BIn development

    Show-me teaching

    Film a person doing the task on a phone; the motion becomes a draft program for the arm.

  3. AI-CIn development

    Vision pick

    A camera finds parts in a jumbled bin or on a moving belt and picks them, with no fixtures to build.

  4. AI-DIn development

    Cell designer

    Describe your workshop and the job; it suggests the machine, the layout and an estimated payback.

  5. AI-EIn development

    Predictive care

    It watches motor current and vibration and warns before a joint wears out, so a machine is serviced, not stopped.

  6. AI-FIn development

    Safety watch

    Cameras watch the space around a cobot and slow it as a person comes close, then speed it back up.

Sheet 03 / 07Dwg HAL-UCScale NTS

Chapter 3

Use cases

The work these machines are for.

Use cases

Six jobs that South African businesses do by hand today, and how a Halcyon machine, taught from the Pendant, could take them on. Drawn as illustrations; every figure is an example.

UC-01HAL-C6 Bench cobot

Bakery end of line

  1. 01 Problem

    4 am. Crate after crate.

    Today two bakers lift every crate of bread off the line and stack it on a pallet by hand, bending and twisting from the first batch to the last.

  2. 02 Entry

    Bolted down. Taught by hand.

    A HAL-C6 is bolted to a stand at the end of the conveyor. The baker guides it to the pick and the first place, and the Pendant records each point.

  3. 03 Running

    Every crate, same pattern.

    The cobot lifts each crate off the line and builds the pallet layer by layer in the taught pattern. It slows if anyone steps into its reach.

  4. 04 Result

    Pallet ready by five.

    A full, square pallet waits for the truck. The bakers check the load on the Pendant, wrap it and go back to the dough.

    • Example: 600 crates stacked a shift
    • Example: 0 crates lifted by hand

UC-02HAL-C6 Bench cobot

Tyre and fitment centre

  1. 01 Problem

    Heavier than it looks.

    Today the fitter crouches under the car with a wheel held at arm's length and lines up the studs by feel. Backs and fingers pay for it, car after car.

  2. 02 Entry

    It holds. You fit.

    A HAL-C6 on a wheeled stand parks beside the lift. On the Pendant the fitter sets the hub height once for the car.

  3. 03 Running

    Lifted, turned, lined up.

    The cobot takes the wheel from the rack, raises it to the hub and turns it until the studs line up. The fitter guides the last few millimetres.

  4. 04 Result

    Four wheels. No strain.

    The fitter stands upright and torques the nuts in a star while the arm fetches the next wheel.

    • Example: 4 wheels in about 8 minutes
    • Example: 0 wheels held at arm's length

UC-03HAL-M1 Lift runner

Clinic store and dispensary

  1. 01 Problem

    The long walk for stock.

    Today a nurse leaves the ward to push a loaded stock cart from the store to the dispensary, down the corridor and back, many times a day.

  2. 02 Entry

    Shown the route once.

    A HAL-M1 Lift runner maps the building on its first drive. On the Pendant the store team drops the stops: store, dispensary, charge.

  3. 03 Running

    Under, up and away.

    It slides under the cart, lifts it and drives the route. When someone crosses, its scanner sees them and it stops, then carries on.

  4. 04 Result

    Stock arrives. Nurses stay.

    The cart is docked at the dispensary and the runner is back on charge. The nurse never left the patients.

    • Example: 3.2 km of walking saved a day
    • Example: 22 runs a day, store to dispensary

UC-04HAL-R4 SCARA

Electronics assembly bench

  1. 01 Problem

    Tweezers, a loupe, all day.

    Today a technician places small parts onto boards by hand under a loupe. Hours of close work, and a part put in the wrong way round is found late.

  2. 02 Entry

    The board sets the origin.

    A HAL-R4 SCARA and an overhead camera go on the bench. The Pendant finds the board's two fiducial marks and loads the placement list.

  3. 03 Running

    Pick. Look. Place.

    The SCARA picks a part from the feeder, shows it to the camera and places it on its pads. Each placement is checked before the next.

  4. 04 Result

    Checked before it leaves.

    The finished board leaves with a check for every part. The technician takes the rework and the next order.

    • Example: 1,400 parts placed an hour
    • Example: 100 % of parts seen by the camera

UC-05HAL-C6 Bench cobot

Steel fabrication shop

  1. 01 Problem

    The same seam, all day.

    Today a welder in a mask runs every joint of a burglar-bar gate by hand, bent over the table in the fumes, seam after seam, frame after frame.

  2. 02 Entry

    Teach the seam, not the code.

    A HAL-C6 with a welding torch is bolted to the table. The welder hand-guides the torch along the first joints and the Pendant records each seam.

  3. 03 Running

    Bead after bead.

    The cobot welds the frame in the taught order at a steady speed and angle, while the welder fits the next set of bars in the jig.

  4. 04 Result

    One done. Next jigged.

    A finished gate comes off the table. The welder grinds, checks and loads the next frame. Burglar bars and trailer chassis are taught the same way.

    • Example: 22 seams in about 20 minutes
    • Example: 2 tables run by one welder

UC-06HAL-R4 SCARA

Fruit packhouse

  1. 01 Problem

    Every orange, by eye.

    Today packers stand at the line all season, picking blemished fruit out by eye and packing cartons by hand, shift after shift.

  2. 02 Entry

    The camera learns the grade.

    A HAL-R4 SCARA goes beside the line under a camera. On the Pendant the packhouse sets the carton pattern and shows the camera what a reject looks like.

  3. 03 Running

    Graded. Picked. Packed.

    The camera grades every fruit as it passes. The SCARA lifts class one fruit into the carton in pattern and lets the rest run on.

  4. 04 Result

    Cartons full. People on quality.

    Full cartons run on to the palletiser. The packers watch quality and handle the exceptions.

    • Example: 40 fruit packed a minute
    • Example: 1 camera grading every fruit

Sheet 04 / 07Dwg HAL-MScale NTS

Chapter 4

The machines

Compact robots for small and mid-sized businesses.

The machines

Compact industrial robots for small and mid-sized businesses, on standard compute and standard drives, every one of them taught from the Pendant. Concepts, in development.

  1. HAL-C6

    Bench cobot, live model

    Concept model. Proportions are design targets.

    J2J3J4J5J6J1TCPR 260Z 290SIDE ELEVATION, PLANE OF THE ARMJ1 0.0 deg, view turns with the base
    The live model loads as you reach it

    HAL-C6Concept

    Bench cobot

    For: Workshops, packing rooms and labs

    A six-axis collaborative arm that works beside people on an ordinary bench.

    Six joints with torque sensing, so it slows and stops on contact instead of needing a cage. Machine tending, packing, screwdriving and lab handling. Taught from the Halcyon Pendant by jogging or by hand-guiding it to each point.

    Parts list for the Bench cobot
    ItemQtyDescription
    11Controller, Raspberry Pi Compute Module 5 class, real-time core
    26Joint modules: servo motor, harmonic gearbox, absolute encoder, torque sensing
    31EtherCAT bus to every joint
    41Tool flange, ISO 9409, swappable grippers
    51Halcyon Pendant licence
    Title
    Bench cobot
    Dwg no.
    HAL-C6-001
    Scale
    NTS
    Sheet
    1 of 9
    Rev
    A
    Status
    Concept
    Date
    31.10.2026
    Drawn
    Halcyon Robotics
  2. HAL-R4

    SCARA, live model

    Concept model. Proportions are design targets.

    J1J2J4R 332Z 700 to 150PLAN, WITH QUILL STROKE
    The live model loads as you reach it

    HAL-R4Concept

    SCARA

    For: Assembly, kitting and fast pick-and-place

    A four-axis SCARA arm for fast, repeatable picks across a flat work area.

    Two horizontal links swing the tool across the table while a ball screw lifts and turns it. Fast where a six-axis arm is overkill: placing parts, filling trays, kitting orders. A camera on the cell finds each part before the pick.

    Parts list for the SCARA
    ItemQtyDescription
    11Controller with vision input
    22Horizontal joints, servo and gearbox
    31Ball screw spline, Z and rotation
    41Overhead camera
    51Halcyon Pendant licence
    Title
    SCARA
    Dwg no.
    HAL-R4-001
    Scale
    NTS
    Sheet
    2 of 9
    Rev
    A
    Status
    Concept
    Date
    31.10.2026
    Drawn
    Halcyon Robotics
  3. HAL-M1

    Lift runner, live model

    Concept model. Proportions are design targets.

    900600PLAN, ROUTE AND SAFETY FIELDProtective field 573 mm from centre at 3 mm/s
    The live model loads as you reach it

    HAL-M1Concept

    Lift runner

    For: Small warehouses, clinic stores and production floors

    An autonomous mobile robot that slides under a cart or shelf, lifts it and moves it.

    Laser scanner and cameras for mapping and safety, a lift deck for carts and shelf units. It learns routes on site, stops for people, and is given its jobs from the same Pendant that programs the arms, so an arm and a runner can hand work to each other.

    Parts list for the Lift runner
    ItemQtyDescription
    11Controller, Jetson class, for mapping and vision
    22Drive modules with encoders and brakes
    31Safety laser scanner and depth cameras
    41Lift deck
    51Battery pack and charging contacts
    Title
    Lift runner
    Dwg no.
    HAL-M1-001
    Scale
    NTS
    Sheet
    3 of 9
    Rev
    A
    Status
    Concept
    Date
    31.10.2026
    Drawn
    Halcyon Robotics
  4. HAL-P4

    Palletiser, live model

    Concept model. Proportions are design targets.

    CURTAIN MADESWR 915LIFT 1670PLAN, LAYER 1 OF 4, PATTERN A0 of 20 cases placed; each layer mirrors the one below
    The live model loads as you reach it

    HAL-P4Concept

    Palletiser

    For: Bakeries, bottlers, FMCG packers and distributors

    A column-and-arm cell that stacks cases onto a pallet at the end of a packing line.

    Cases arrive on a conveyor; the arm lifts each one with a vacuum gripper and builds the pallet layer by layer in a pattern taught on the Pendant. A light curtain guards the pallet bay so a person can change pallets safely.

    Parts list for the Palletiser
    ItemQtyDescription
    11Controller with conveyor and safety inputs
    24Axes: column lift, swing, reach, wrist turn
    31Vacuum case gripper
    41Infeed conveyor and pallet bay light curtain
    51Halcyon Pendant licence with pattern library
    Title
    Palletiser
    Dwg no.
    HAL-P4-001
    Scale
    NTS
    Sheet
    4 of 9
    Rev
    A
    Status
    Concept
    Date
    31.10.2026
    Drawn
    Halcyon Robotics
  5. HAL-W6

    Weld cell, live model

    Concept model. Proportions are design targets.

    SEAM 1: 0 OF 160SEAM 2: 0 OF 160TIPPLAN, FIXTURE TABLE, TWO FILLET SEAMSArc off
    The live model loads as you reach it

    HAL-W6Concept

    Weld cell

    For: Small fabrication shops: gates, burglar bars, trailers

    A cobot welding table for small fabrication shops, taught by moving the torch to each seam.

    A six-axis cobot carries a MIG torch over a fixture table. The welder guides the torch along each seam, records it, and the cell repeats the weld on every part. A screened table and fume extraction come with it.

    Parts list for the Weld cell
    ItemQtyDescription
    11HAL-C6 Bench cobot with weld wrist
    21MIG torch, wire feeder interface
    31Fixture table with clamping grid
    41Weld screens and fume extraction
    51Halcyon Pendant licence with weld programs
    Title
    Weld cell
    Dwg no.
    HAL-W6-001
    Scale
    NTS
    Sheet
    5 of 9
    Rev
    A
    Status
    Concept
    Date
    31.10.2026
    Drawn
    Halcyon Robotics
  6. HAL-S2

    Solar panel cleaner, live model

    Concept model. Proportions are design targets.

    CLEANED 0 OF 6100-34025 degSECTIONFACE OF THE ROW, LOOKING AT THE GLASSBrush 0 rpm; edge sensors on the glass
    The live model loads as you reach it

    HAL-S2Concept

    Solar panel cleaner

    For: Solar farms, farms and commercial roofs

    A tracked robot that crawls a row of solar panels and brushes off dust without water.

    It rides along the row on rubber tracks, a rotating brush sweeps the glass ahead of it, and edge sensors keep it on the panels. At the end of the row it is lifted or driven to the next. Cleaning is scheduled from the Pendant.

    Parts list for the Solar panel cleaner
    ItemQtyDescription
    11Controller with edge and tilt sensors
    22Rubber track drives
    31Rotating dry brush
    41Battery and small solar charging panel
    51Halcyon Pendant licence with schedules
    Title
    Solar panel cleaner
    Dwg no.
    HAL-S2-001
    Scale
    NTS
    Sheet
    6 of 9
    Rev
    A
    Status
    Concept
    Date
    31.10.2026
    Drawn
    Halcyon Robotics
  7. HAL-T1

    Wheel handler, live model

    Concept model. Proportions are design targets.

    Z 430HOLES 31.0 DEG OFFHUB FACE, 5 x 114.3 PCDFRONT ELEVATION, ALONG THE HUB AXISRoller turn 0.0 deg; load 0 kg
    The live model loads as you reach it

    HAL-T1Concept

    Wheel handler

    For: Tyre and fitment centres, fleet depots

    A powered lift that takes a wheel from the rack, raises it to the hub and turns it until the studs line up.

    Heavy wheels are the injury risk in every fitment bay. The handler grips the tyre, lifts it, and turns it slowly to align the studs while the fitter guides it home. Wheel sizes are stored as programs on the Pendant.

    Parts list for the Wheel handler
    ItemQtyDescription
    11Controller with load sensing
    21Lift column, servo driven
    31Tyre gripper with rotating rollers
    41Wheeled base with brakes
    51Halcyon Pendant licence
    Title
    Wheel handler
    Dwg no.
    HAL-T1-001
    Scale
    NTS
    Sheet
    7 of 9
    Rev
    A
    Status
    Concept
    Date
    31.10.2026
    Drawn
    Halcyon Robotics
  8. HAL-V3

    Vision sorter, live model

    Concept model. Proportions are design targets.

    CAMERAREJECT 0GRADE B 0GRADE A 0JETS 1JETS 2AABARABBELT 3000, 600 mm/sPLAN, GRADING AND THREE LANESDefect: reject. Clean under 72 mm: grade B. Clean 72 mm and over: grade A.
    The live model loads as you reach it

    HAL-V3Concept

    Vision sorter

    For: Fruit packhouses, nut processors and recyclers

    A belt, a camera and air jets that grade and sort produce or recycling as it passes.

    Items pass under a camera on a belt; a vision model grades each one by size, colour and defects, and timed air jets push it into the right lane. Grades and thresholds are set from the Pendant.

    Parts list for the Vision sorter
    ItemQtyDescription
    11Controller, Jetson class, for vision
    21Belt conveyor with encoder
    31Camera and lighting hood
    41Air jet bank and valves
    53Output lanes
    Title
    Vision sorter
    Dwg no.
    HAL-V3-001
    Scale
    NTS
    Sheet
    8 of 9
    Rev
    A
    Status
    Concept
    Date
    31.10.2026
    Drawn
    Halcyon Robotics
  9. HAL-K1

    Pendant retrofit kit, live model

    Concept model. Proportions are design targets.

    PENDANTenabling deviceand E-STOPHALCYON CABINETDRIVE 1DRIVE 2DRIVE 3DRIVE 4DRIVE 5DRIVE 6J1 MOTOR, ENCODER0.0 degJ2 MOTOR, ENCODER-0.6 degJ3 MOTOR, ENCODER62.9 degJ4 MOTOR, ENCODER27.7 degJ5 MOTOR, ENCODER0.0 degJ6 MOTOR, ENCODER0.0 degWIRING, PENDANT TO CABINET TO THE OLDER ARMThe old controller and pendant are retired; motors and encoders stay.
    The live model loads as you reach it

    HAL-K1Concept

    Pendant retrofit kit

    For: Workshops with an older, second-hand industrial arm

    A controller box and the Halcyon Pendant that bring an older industrial arm back under a modern teach pendant.

    Many workshops can buy a used industrial arm cheaply but not its controller or pendant. The retrofit kit replaces the old controller with a Halcyon one, wired to the arm's motors and encoders, so it is taught from a tablet like every Halcyon machine.

    Parts list for the Pendant retrofit kit
    ItemQtyDescription
    11Halcyon controller cabinet
    26Servo drive modules
    31Wiring harness and encoder interfaces
    41Enabling device and E-STOP
    51Halcyon Pendant licence
    Title
    Pendant retrofit kit
    Dwg no.
    HAL-K1-001
    Scale
    NTS
    Sheet
    9 of 9
    Rev
    A
    Status
    Concept
    Date
    31.10.2026
    Drawn
    Halcyon Robotics

Sheet 05 / 07Dwg HAL-CScale NTS

Chapter 5

The company

Automation priced for the workshop, not the car plant.

The company

Machines you can understand.

Halcyon Robotics is a robotics company in South Africa, with its registration in progress. We build two things: the Halcyon Pendant, a virtual teach pendant that runs in a browser on a tablet or laptop, and a small range of compact robots it programs.

Industrial automation has been priced for car plants. We design for the workshop, the packing room, the clinic store and the small warehouse: machines on standard compute and standard drives, that a business can afford, maintain and teach itself. Every machine on this page is in development, and every figure on it is a design target, not a measured result.

Technology

Four ideas run through every robot we design.

  • Affordable by design

    Standard parts throughout: Raspberry Pi Compute Module or Jetson-class controllers, EtherCAT servo drives, off-the-shelf gearboxes. A broken part is a part you can order, not a service call.

  • One platform, many robots

    The robots share joints, grippers, a controller and software. A new robot is a new arrangement of parts we already know, not a new start.

  • Programmed by teaching

    Every machine is taught the way industrial robots are: move it to a point, record it, play the program back. Our virtual teach pendant runs in a browser, so a tablet is the controller.

  • Drawn and explained

    Every part is drawn and every function is explained, the way an engineer documents a machine. People should see what a robot is doing and why.

Sheet 06 / 07Dwg HAL-TScale NTS

Chapter 6

The team

The people building Halcyon Robotics.

The team

The people building Halcyon Robotics.

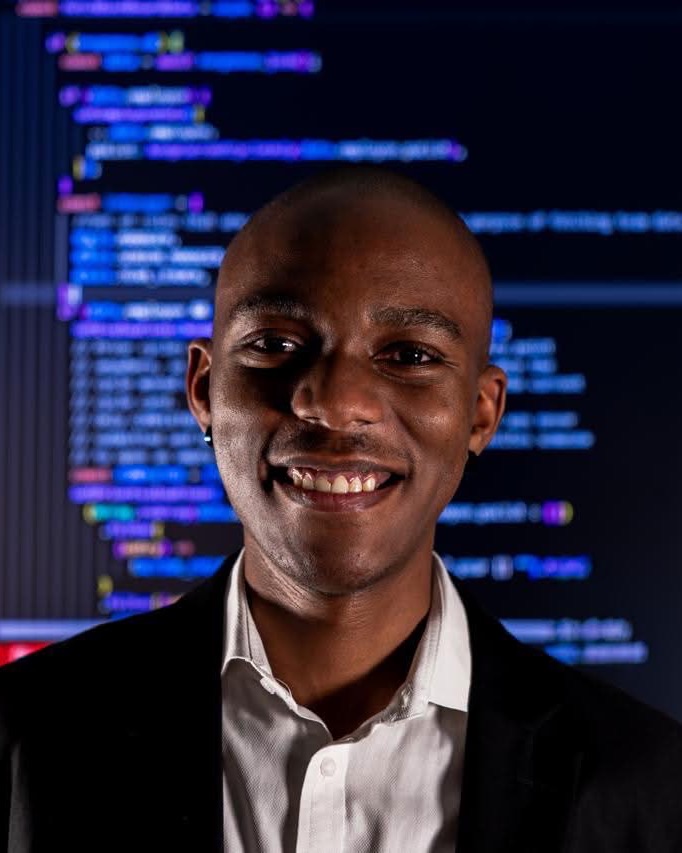
  • Vuyo Nkadimeng, Founder

    Vuyo Nkadimeng

    Founder

    Software engineering leader and director of Quantyx, a South African studio that publishes native iOS apps, and of Africortex, an IT services company. Leads the platform, the pendant software and the site.

  • Dr Edward Nkadimeng

    Co-founder

    Researcher at the National Research Foundation's iThemba LABS. Received the 2025 Presidential Award of the African Youth in Artificial Intelligence and Robotics Competition, the highest honour of the Presidential African Youth in AI and Robotics Initiative.

Sheet 07 / 07Dwg HAL-WScale NTS

Chapter 7

Work with us

Clients, investors, careers and the press.

Work with us

Each request opens in your own email app, addressed to us, with a subject and a few lines to fill in.

Clients and partners

Tell us about the work you want automated, or a partnership you have in mind. Tick anything you are asking about.

What you are asking about

Write an enquiry

Investors

We will send the deck: how the company is built, the platform the robots share, and where each robot stands.

Request the deck

Careers

There are no roles listed yet. Send an open application and tell us what you would like to build.

Send an open application

Press

For questions about the company and its robots, and for images and interviews.

Write to us for press

Contact

Halcyon Robotics

South Africa

Write to Halcyon Robotics